Grippers

OPT

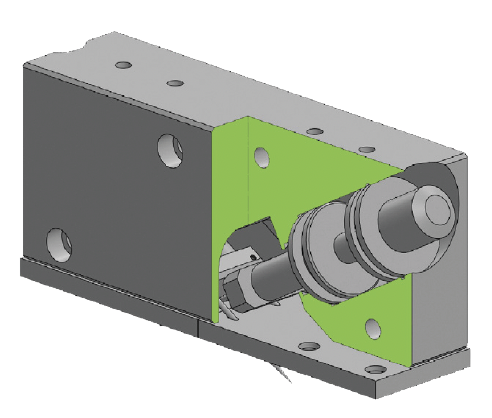
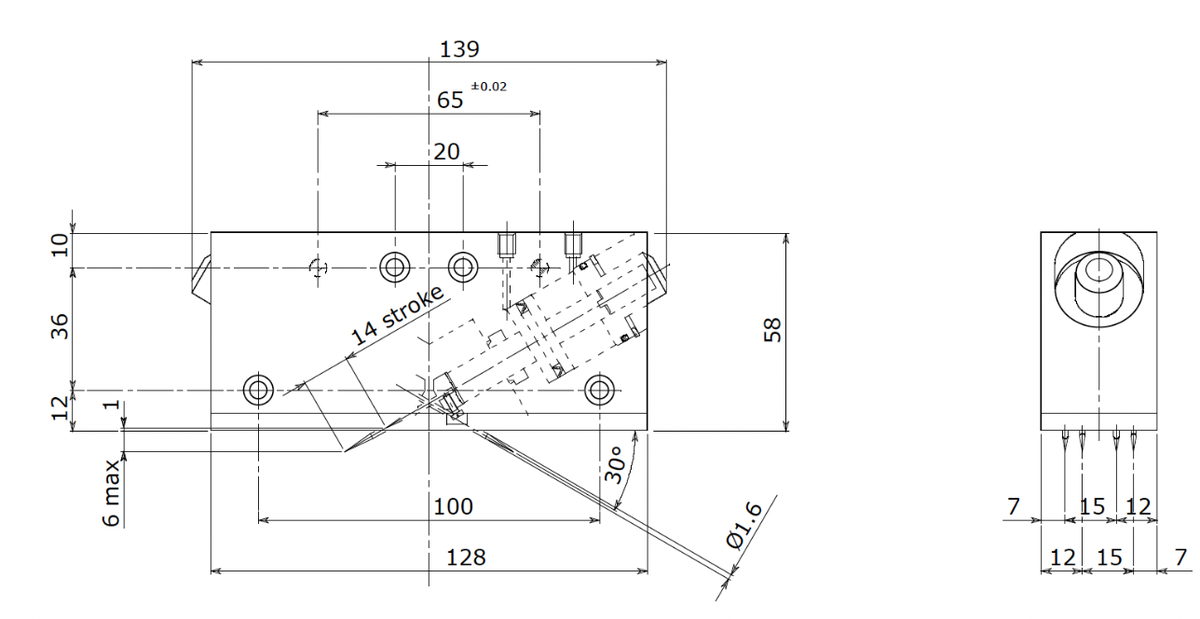
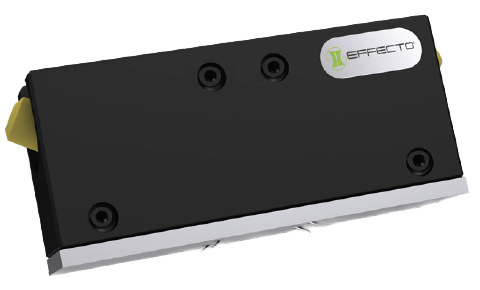
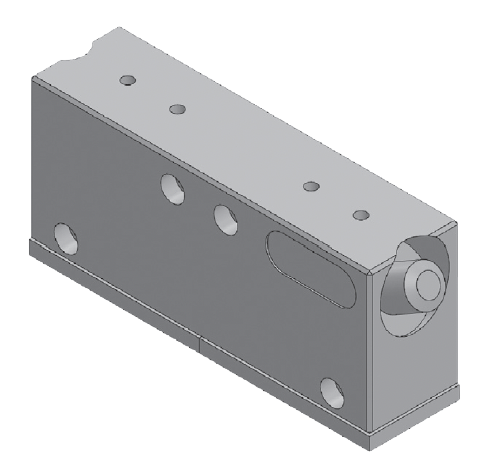
OPT is a pneumatic needle gripper suitable for handling non-rigid and very porous materials (primarily textiles).

Models

OPT is a pneumatic needle gripper suitable for the handling of non-rigid and very porous materials (primarily textiles).

Advantages

  • Extremely short cycle time for high-speed applications.
  • High needle inclination for secure workpiece locking.
  • Robust body; suitable for heavy-duty applications.
  • High repeatability.
  • Long service life.
Metric Imperial
Model & Description Data Sheet 3D Model Weight Stroke Per Needle Fluid Consumption Double Stroke Recommended Workpiece Weight Repeat Accuracy Theoretical thrust for each needle @ 6 bar
OPT-34-25-P-14-L-SM-8-N-B-N 0.75 kg1.65 lb 14 mm0.55 in 26 cm³1.59 in³ 1.48 kg3.20 lb ±0.05 mm±0.002 in 147.5 N33.2 lbf
OPT-34-25-P-14-L-SM-8-N-B-N
Data Sheet
3D Model
Weight
0.75 kg1.65 lb
Stroke Per Needle
14 mm0.55 in
Fluid Consumption Double Stroke
26 cm³1.59 in³
Recommended Workpiece Weight
1.48 kg3.20 lb
Repeat Accuracy
±0.05 mm±0.002 in
Theoretical thrust for each needle @ 6 bar
147.5 N33.2 lbf

Designs

EFFECTO pneumatic grippers are designed for durability, with a wedge-hook mechanism that delivers high power transmission and repeatable, synchronized gripping cycle after cycle.

Available across 30 versions and multiple sizes, from compact grippers for tight workspaces to larger models for heavy-duty applications, each is built with superior jaw guidance for precise handling and easy maintenance in harsh environments.

Downloads

Model & Description Data Sheet 3D Model
OPT-34-25-P-14-L-SM-8-N-B-N
Data Sheet
3D Model

Connect with EFFECTO

Find the right tool for your application today

Request 3D Model Download

* Denotes Required Field